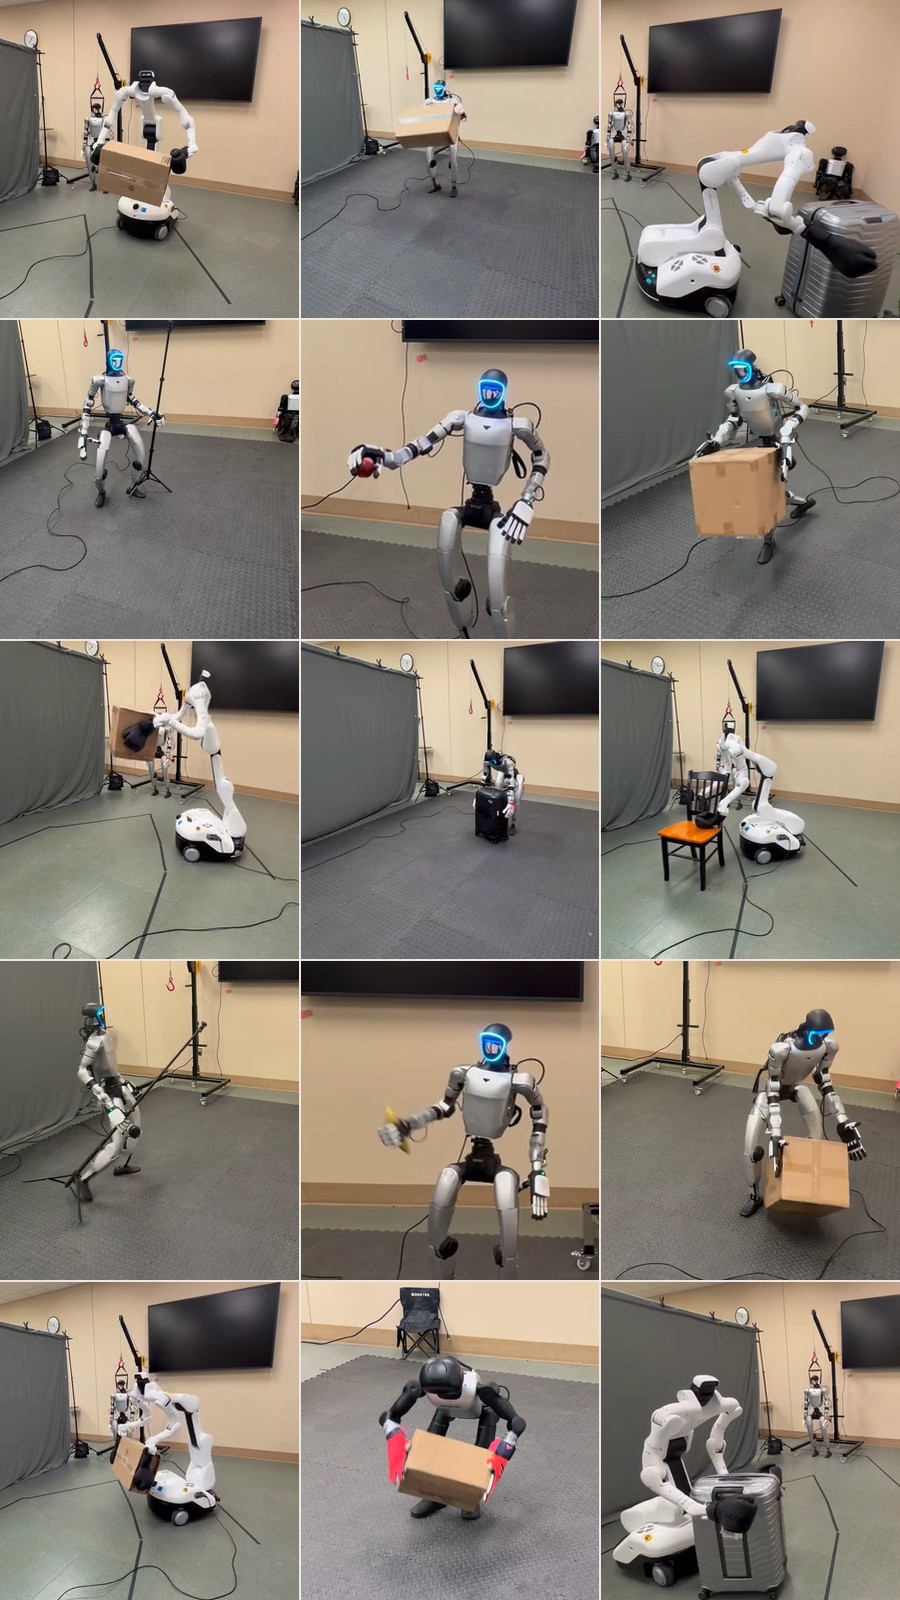
A data flywheel for humanoid loco-manipulation.
InterMimicGen
Scaling humanoid loco-manipulation through self-evolving motion imitation.
Scroll to explore ↓
01 / Deployment
InterMimicGen
for physical robots.
The idea
One human interaction can become many robot motions.
Scale like MimicGen, ground like InterMimic: every physically executed motion becomes new data.
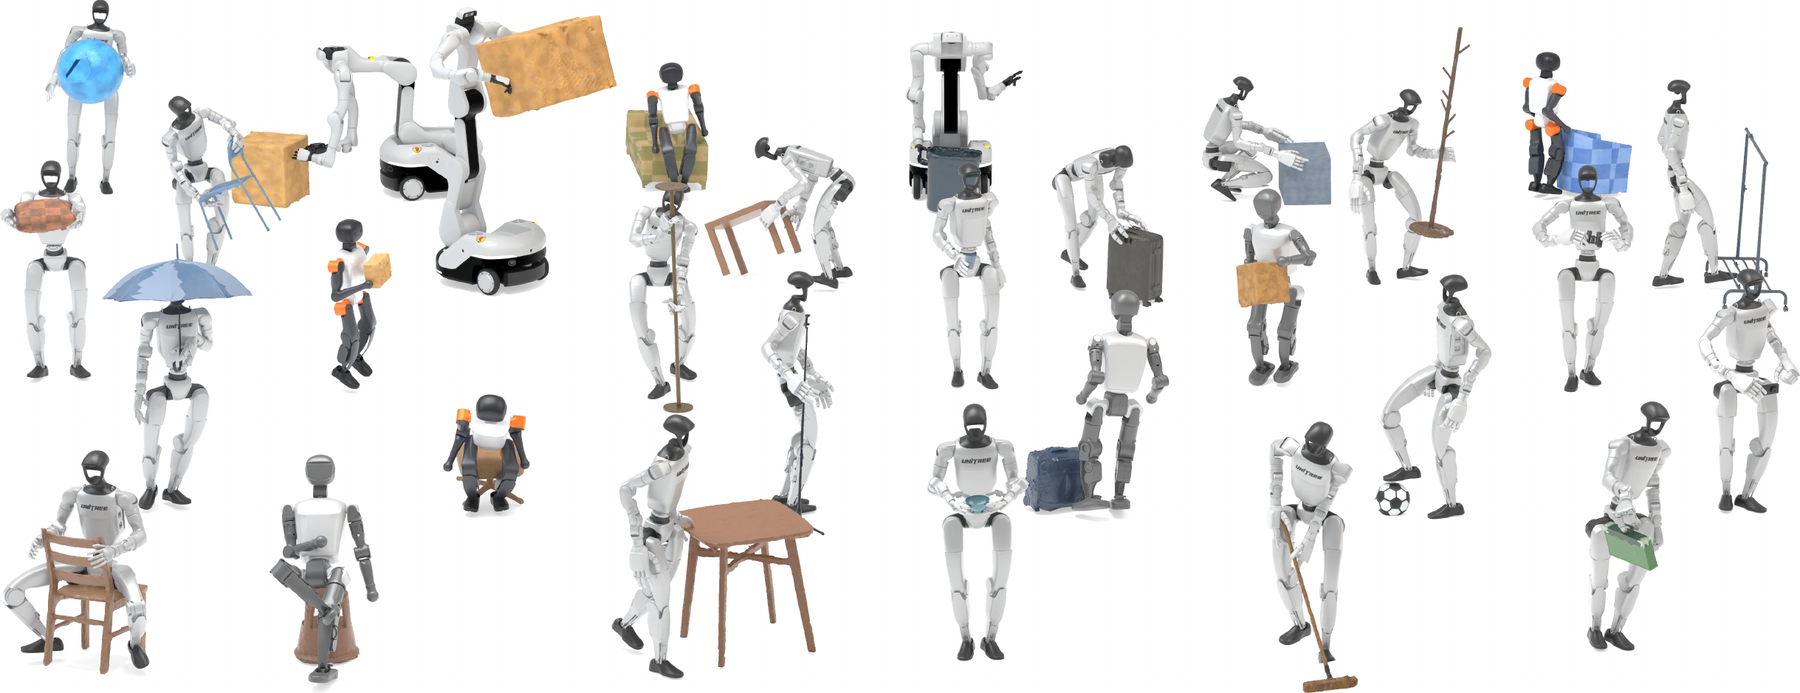
02 / Retargeting
InterMimicGen
for resolving the embodiment gap.
02.1
Across objects
02.2
Across embodiments
02.3
Against baselines
03 / Tracking
InterMimicGen
for large-scale motion imitation.
03.1
Across objects
03.2
Across robot configurations
Tripod
Racket
04 / Evolution
InterMimicGen
for self-evolution.
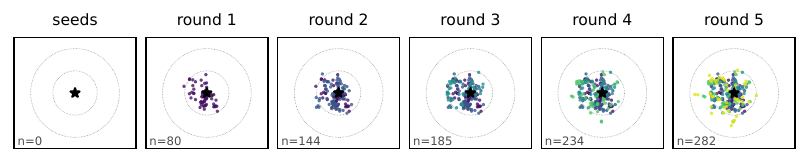
Local edits.
Growing reach.
Accepted physical executions reach farther from the original interaction over successive rounds.